LandOffer
Job search
Embedded Systems Portfolio: Make Hardware Behavior Reviewable Remotely
A complete fictional board case and an executed host debounce model show how to present behavior, versions and measurement limits without requiring the reviewer’s hardware.
An embedded systems portfolio should let a reviewer understand the hardware behavior without owning your board. Include hardware and firmware versions, a readable demonstration, measurement conditions and your specific contribution. Keep observed board results separate from host simulations, expected behavior and unresolved questions.
This guide checks primary manufacturer and RTOS documentation on October 21, 2026. The board case and all its measurements are fictional. The only executed exercise is an original AI-authored host model using synthetic button samples; no hardware, firmware flashing, USB, serial port or measurement instrument was accessed. LandOffer publishes this guide and offers job-search tools; browse recent roles to choose the embedded responsibility your evidence should explain.
Give the reviewer a behavior to inspect
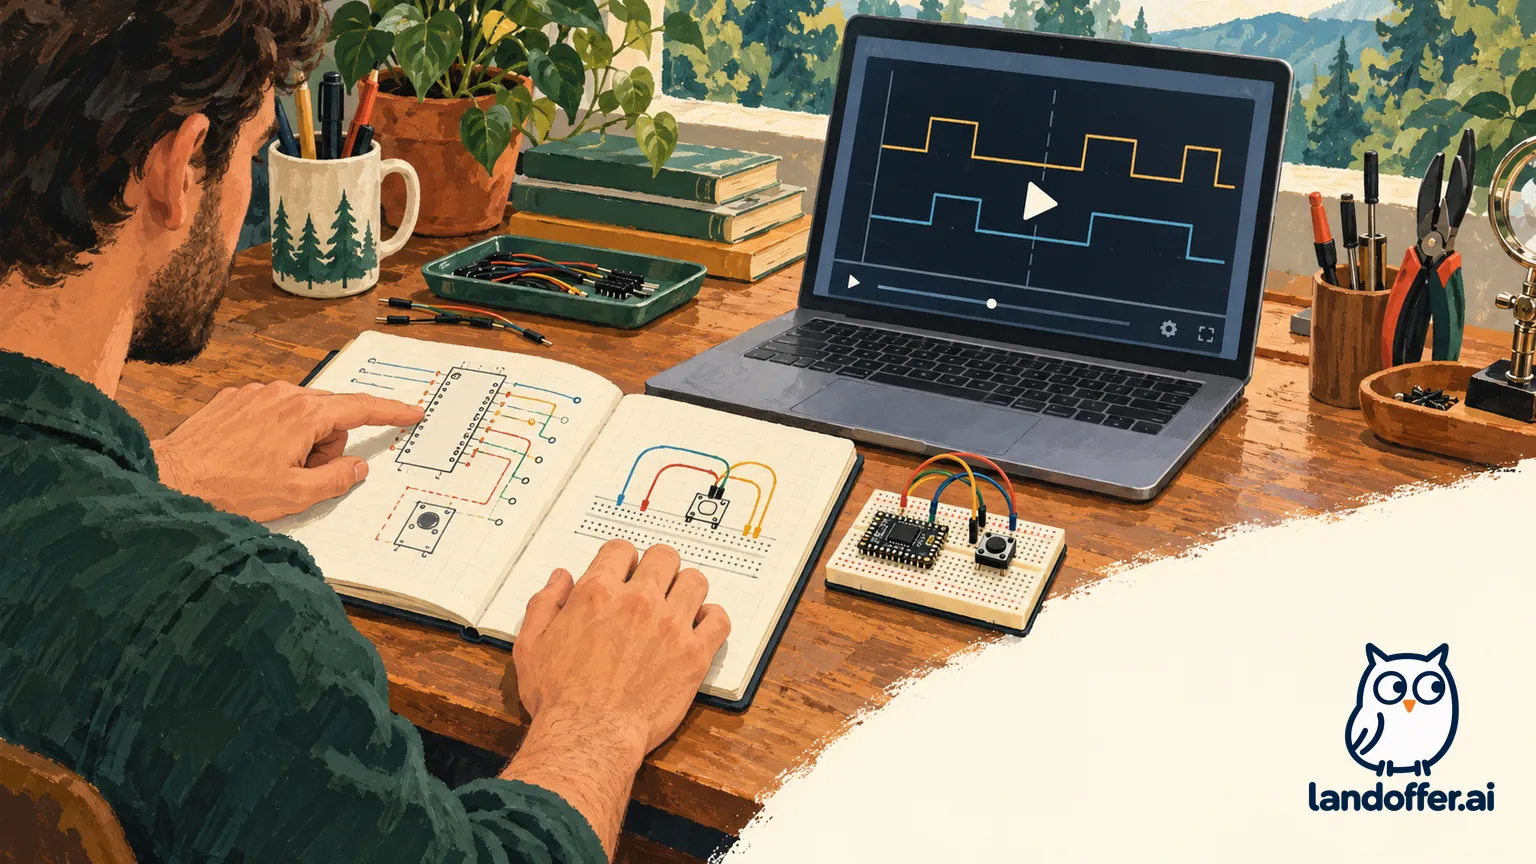
Start with a concrete interaction: a mechanical button should produce one accepted press after a defined stable interval, while brief chatter should not create extra presses. A reviewer can inspect that behavior through a wiring diagram, a trace and a short annotated demonstration. Replace a broad “built firmware” claim with the behavior and evidence you want the reviewer to evaluate.
Define what counts as success. Is the requirement about logical state transitions, response time, power, communication reliability or recovery? Each needs different evidence. A correct host state machine does not demonstrate electrical noise immunity. A successful button press does not establish interrupt latency or long-term reliability.
Give the case a small boundary. For the example here, the work is a button-event demonstration with a diagnostic output. It is not an industrial control system, a safety certification or a production device. Keep unrelated features out of the main explanation so that the reviewer can follow one input, one decision and one observable result.
Match every demonstration to its board, firmware and assembly
Manufacturer names are insufficient version information. Raspberry Pi's Pico documentation distinguishes generations, wireless variants and boards with headers. It also describes version information that may be present in binaries built with its C/C++ SDK. That supports recording the exact specimen and build; it does not prove what was flashed onto your device.
A useful inventory connects the board photograph, assembly revision, bill of materials, pin map, firmware revision and configuration. Keep application version separate from a manufacturer PCB revision. If the silkscreen revision is unreadable, record that gap rather than inventing it from the product name.
Use the manufacturer's actual pin diagram. The inspected Pico 1/Pico 2 pinout PDF identifies GP15 at physical pin 20, GP14 at pin 19 and ground at pin 18. Signal names and header positions are different labels; provide both when describing a connection. This article visually inspected the official diagram rather than inferring positions from GPIO numbers.
For your own project, include a legible schematic and the relevant voltage and interface assumptions. A photograph can help show the assembly, but it should not force the reviewer to trace every wire by color. Do not infer safe electrical operation or compatible input thresholds from an unlabeled board photo.
Worked remote case: a fictional button-event prototype
Fictional candidate Ellis documents a non-wireless Raspberry Pi Pico 2 with headers, local assembly revision A and application version button-demo-v0.3. These are invented project records. The manufacturer PCB revision was not captured, so the case explicitly leaves it unverified. No real board or candidate is being described.
Ellis's completed inventory and test brief is:
| Field | Completed fictional record |
|---|---|
| Hardware | One Pico 2 with headers, specimen U1; one normally-open momentary switch, breadboard, three signal/ground jumper leads and USB cable |
| Input | Switch between GP15, physical pin 20, and GND, physical pin 18; input configured with pull-up and active-low interpretation |
| Diagnostic output | GP14, physical pin 19, changes with the accepted logical state; analyzer channels observe input and diagnostic output with a common ground |
| Power and environment | USB-powered bench setup; stipulated rail reading 3.30 V; room-temperature demonstration, not an environmental test |
| Firmware identity | button-demo-v0.3, local source revision case-rev-03, explicit 20 ms stable-input rule and 1 ms requested sampling period |
| Measurement setup | Fictional two-channel logic analyzer at 1 MHz and handheld voltmeter for the rail reading; channel assignment and trigger recorded |
| Scope | One specimen, one switch and one demonstration sequence; no power, endurance, electromagnetic or safety qualification |
The revision strings are teaching labels, not real commits or download links. The 3.30 V value, capture rate and sampling configuration are stipulated fictional conditions, not measurements obtained by this article. A real portfolio must replace them with its own instrument, configuration and evidence.
The hypothetical demonstration trace records contact activity at 12, 14 and 18 ms, followed by a diagnostic output transition at 39 ms. Ellis's completed interpretation is: “The stipulated trace shows the accepted state changing 21 ms after the last recorded input edge in this capture.” It does not claim every press responds within 21 ms. Requested sampling, scheduler behavior and measurement alignment need their own explanation.
A second stipulated observation records a brief low pulse from 130 to 140 ms with no diagnostic transition. That supports the narrow explanation that this example suppressed that pulse. It does not establish a universal debounce setting for every switch. Ellis includes the input trace and output trace on the same time base so a reviewer can inspect the comparison.
The finished case blurb is: “Button-event prototype documented with assembly revision A, application v0.3, pin mapping and a paired input/diagnostic trace. The fictional demonstration illustrates stable-input acceptance and brief-pulse rejection; additional boards and operating conditions remain untested.” This is an example of scoped writing, not a credential to copy into an application.
Put measurement conditions beside the result
A timestamp needs an origin and unit. Explain whether it comes from an analyzer sample, a hardware timer, an RTOS tick or a host log. If two sources use different clocks, state how they were aligned before subtracting timestamps. USB log arrival time should not silently become the time a pin changed.
Include the instrument configuration, channel assignments, relevant threshold settings and the finite sequence tested. Describe uncertainty where it affects the claim. Record capture-rate and accuracy limits separately, and distinguish the requested sampling interval from observed execution timing.
In a real demonstration, show the action and result together: the input stimulus, the observed output and a pointer to the corresponding trace segment. A short video with captions can make the sequence understandable, while a readable static trace lets the reviewer pause and inspect it. Keep raw permitted evidence available without requiring a specialized instrument application.
Avoid making the recording the only source. State the expected result and actual observation in text, including an unsuccessful case when one occurred. If the board was not tested under load or across voltage and temperature variation, leave those limitations visible rather than hiding them behind a smooth demo.
Separate a host model from target behavior
The current Zephyr gpio-keys binding describes a debounce interval in milliseconds and documents a default of 30 when unspecified. The example here deliberately chooses 20 ms. It is not an assertion that Zephyr's default is 20 or that this Python model implements the driver's full behavior.
Zephyr's custom devicetree GPIO sample also distinguishes board-specific configuration from its native simulator's emulated GPIO controller. That is a useful boundary: behavior exercised without hardware can support software reasoning, while physical wiring and electrical behavior still require target evidence. This article did not build or run Zephyr or its native simulator.
State exactly which layer you executed. A Python state model, an RTOS-native simulation, a target unit test and a physical instrument capture are separate artifacts. Sharing a sample name or an expected output does not make their results interchangeable.
Worked host check: stable states, short pulses and invalid units
This article actually executed a new local Python model over 17 synthetic samples. It starts released, interprets zero as pressed and accepts a changed state only when the current candidate value has persisted for at least 20 ms at a sampled observation. It emits no event while the accepted state remains unchanged.
The completed result ledger is:
| Synthetic segment | Expected model behavior | Actual local result |
|---|---|---|
| Chatter at 10, 14 and 18 ms; low sampled again at 38 ms | Accept the candidate after its stable interval | Pressed at 38 ms |
| Continued low at 60 ms | Do not count a second press | No additional event |
| Release chatter at 75, 80 and 85 ms; high again at 105 ms | Accept stable release | Released at 105 ms |
| Brief low at 130 ms, high at 140 and 160 ms | Suppress the short pulse | No event in that segment |
| Low at 200 and 220 ms, then high at 240 and 260 ms | Accept a second press and release | Pressed at 220 ms; released at 260 ms |
The resulting press count is two. Separate negative cases supplied microsecond units, out-of-order timestamps and a nonbinary input; the model rejected each with an explicit error. The saved script passed eight assertions, including the exact expected transition sequence, short-pulse suppression, a released final state and an unchanged input-file SHA-256 hash. The saved report records Python 3.12.14.
The 38 ms transition is a computed observation in the synthetic sample stream. It is not a measured response time on a Pico, an ISR latency or a statement about a physical switch. The model does not interpolate unseen changes between samples. Its result depends on the provided observations and declared initial state.
The completed engineering decision is to keep the host test as evidence of the stated logical rule, while reserving board-timing and electrical claims for separate measurements. The fictional 39 ms hardware observation above and this actual 38 ms host event therefore remain different evidence classes. Neither is silently presented as a reproduction of the other.
Assemble a case that opens without the hardware
Give the reviewer a clear reading route: project overview, hardware and firmware identity, schematic, annotated demonstration, result ledger, finite checks and limitations. Include static images or ordinary text for the key findings so that specialist viewers and a matching board are optional.
Keep version relationships explicit. If the wiring photograph shows assembly A but the trace came from assembly B, explain the difference. If the code changed after the demonstration, identify which build generated the evidence. A current repository should not make an older video look like proof of a newer firmware revision.
Describe your contribution alongside collaborators' work. Writing the debounce logic, configuring the build, assembling the board and capturing measurements can belong to different people. A teammate's analyzer capture can still be useful evidence when properly attributed; it should not be described as a measurement you personally performed.
For an application, a defensible project bullet names the implemented behavior, evidence and scope. If the work really occurred, it might read: “Implemented a button-event prototype and documented its assembly, firmware revision and paired input/output checks; supplied a host state-model test and a separate target trace.” Use only the parts you actually did and can share.
As you compare recent roles on LandOffer, compare the role’s firmware, board bring-up, interface debugging and validation responsibilities with the evidence your case actually contains. Make the behavior reviewable remotely, preserve the evidence's version and measurement boundaries, and leave untested target conditions clearly identified.